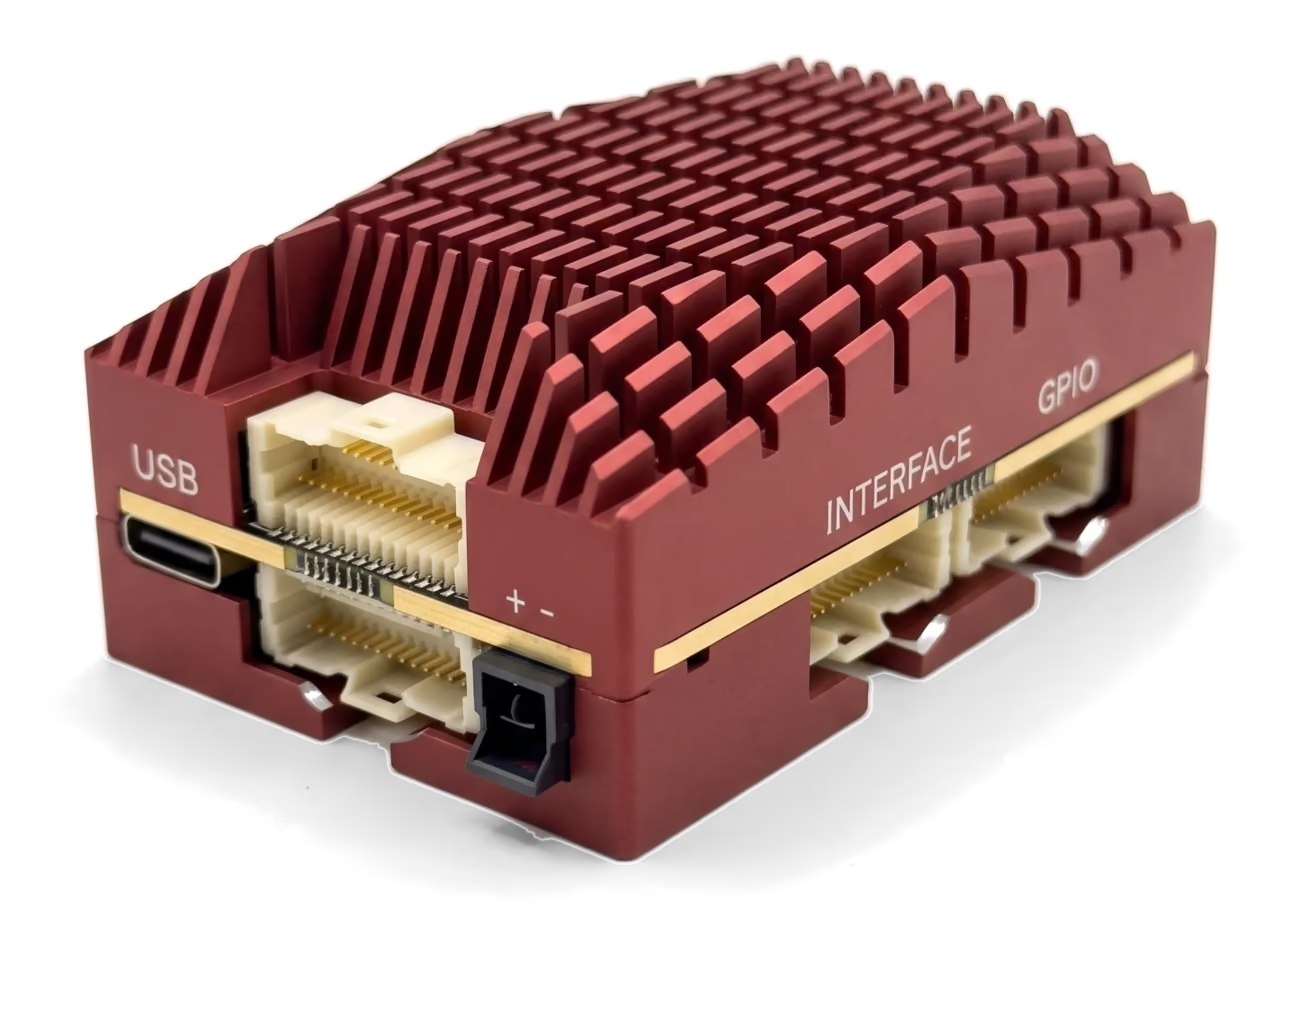
AI on Edge
Open architecture
Plug and play on any platform.
Documented interfaces, a standard Linux target, and ArduPilot or PX4.
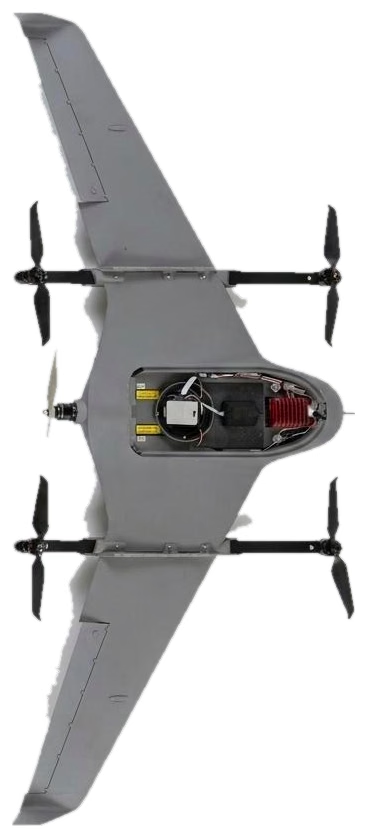
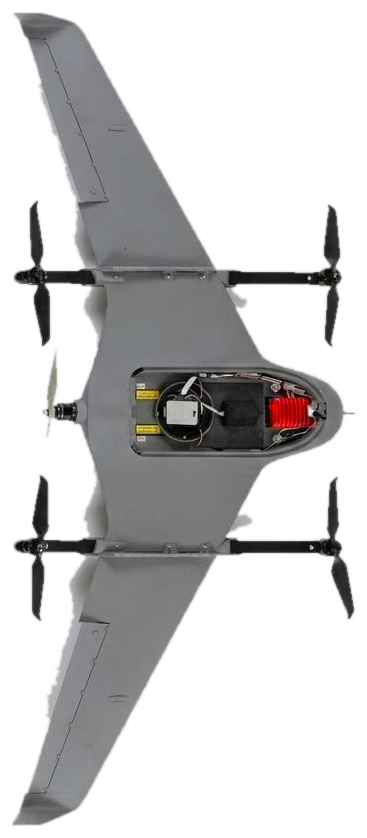
Aerial
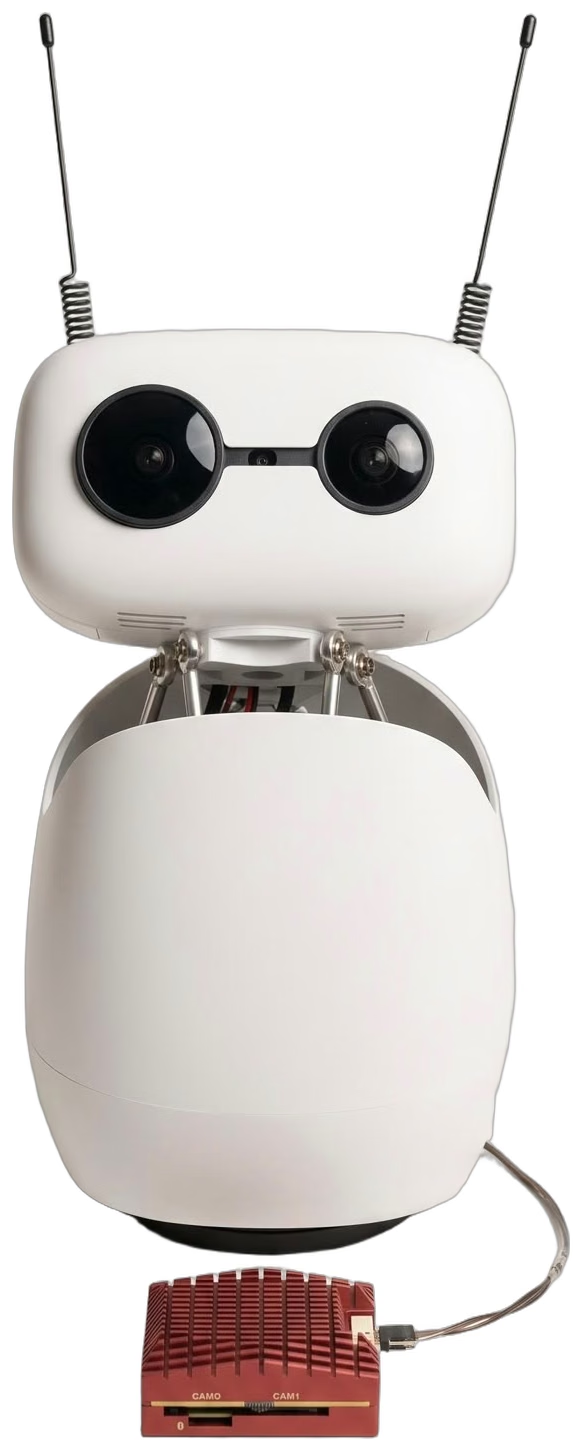
Ground
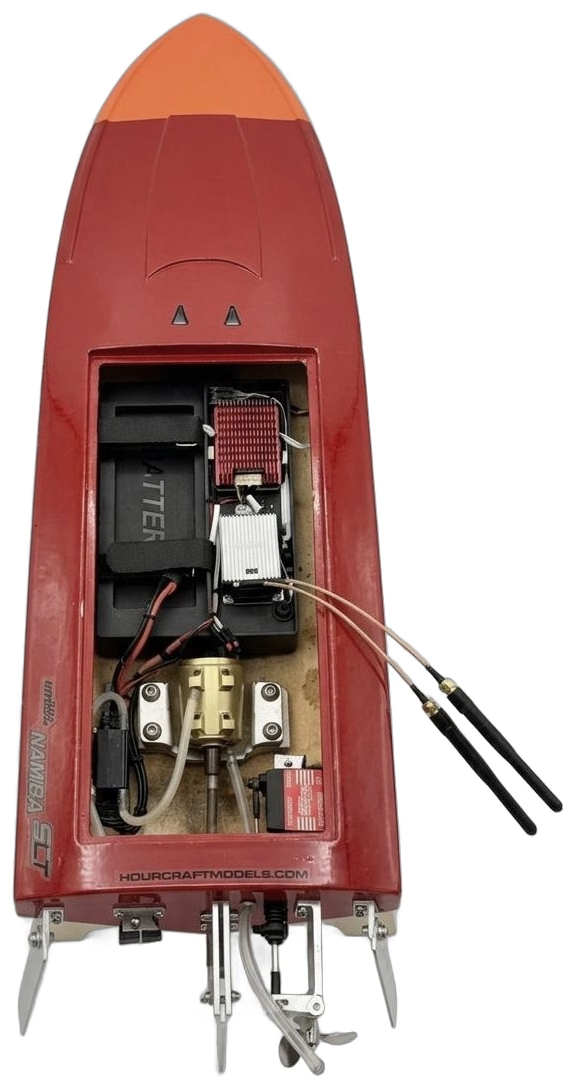
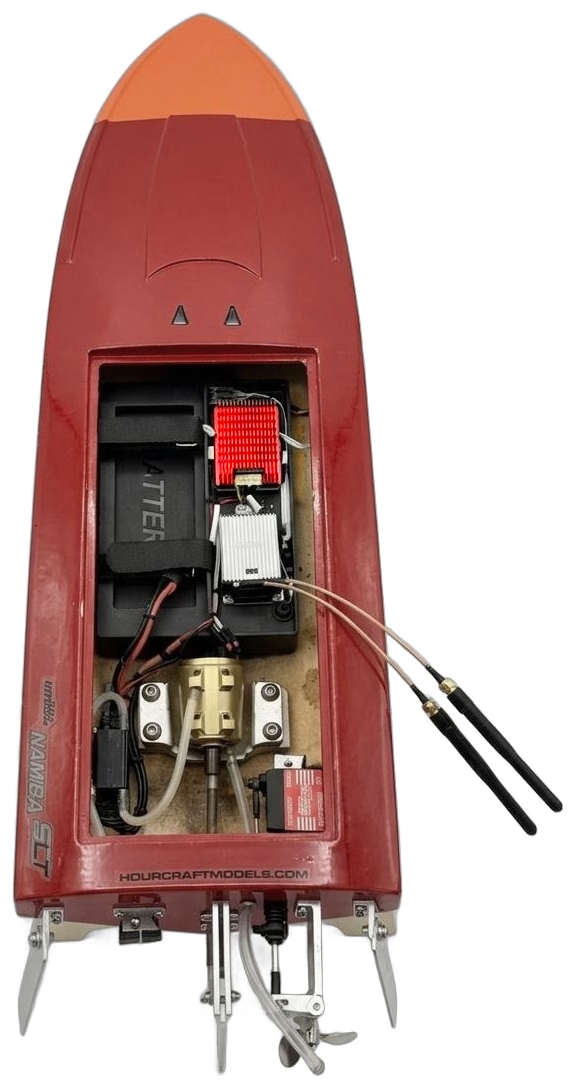
Maritime
- Visual-inertial odometry
GNSS-denied navigation
Continuous positioning from visual and inertial sensors when satellite navigation is jammed, spoofed or unavailable.
- Automatic target recognition
Target recognition and tracking
Recognition and tracking run onboard at high frequency and continue when the link to the ground station drops.
- Visual tracking
Terminal guidance
Select a target with one click on the live video in the ground station, or let onboard detection find one. The platform tracks it frame by frame and closes in, searching again if it loses the target.
- Autonomous landing
Precision landing
Autonomous landing for aircraft, guided by onboard perception, without satellite or ground control links.